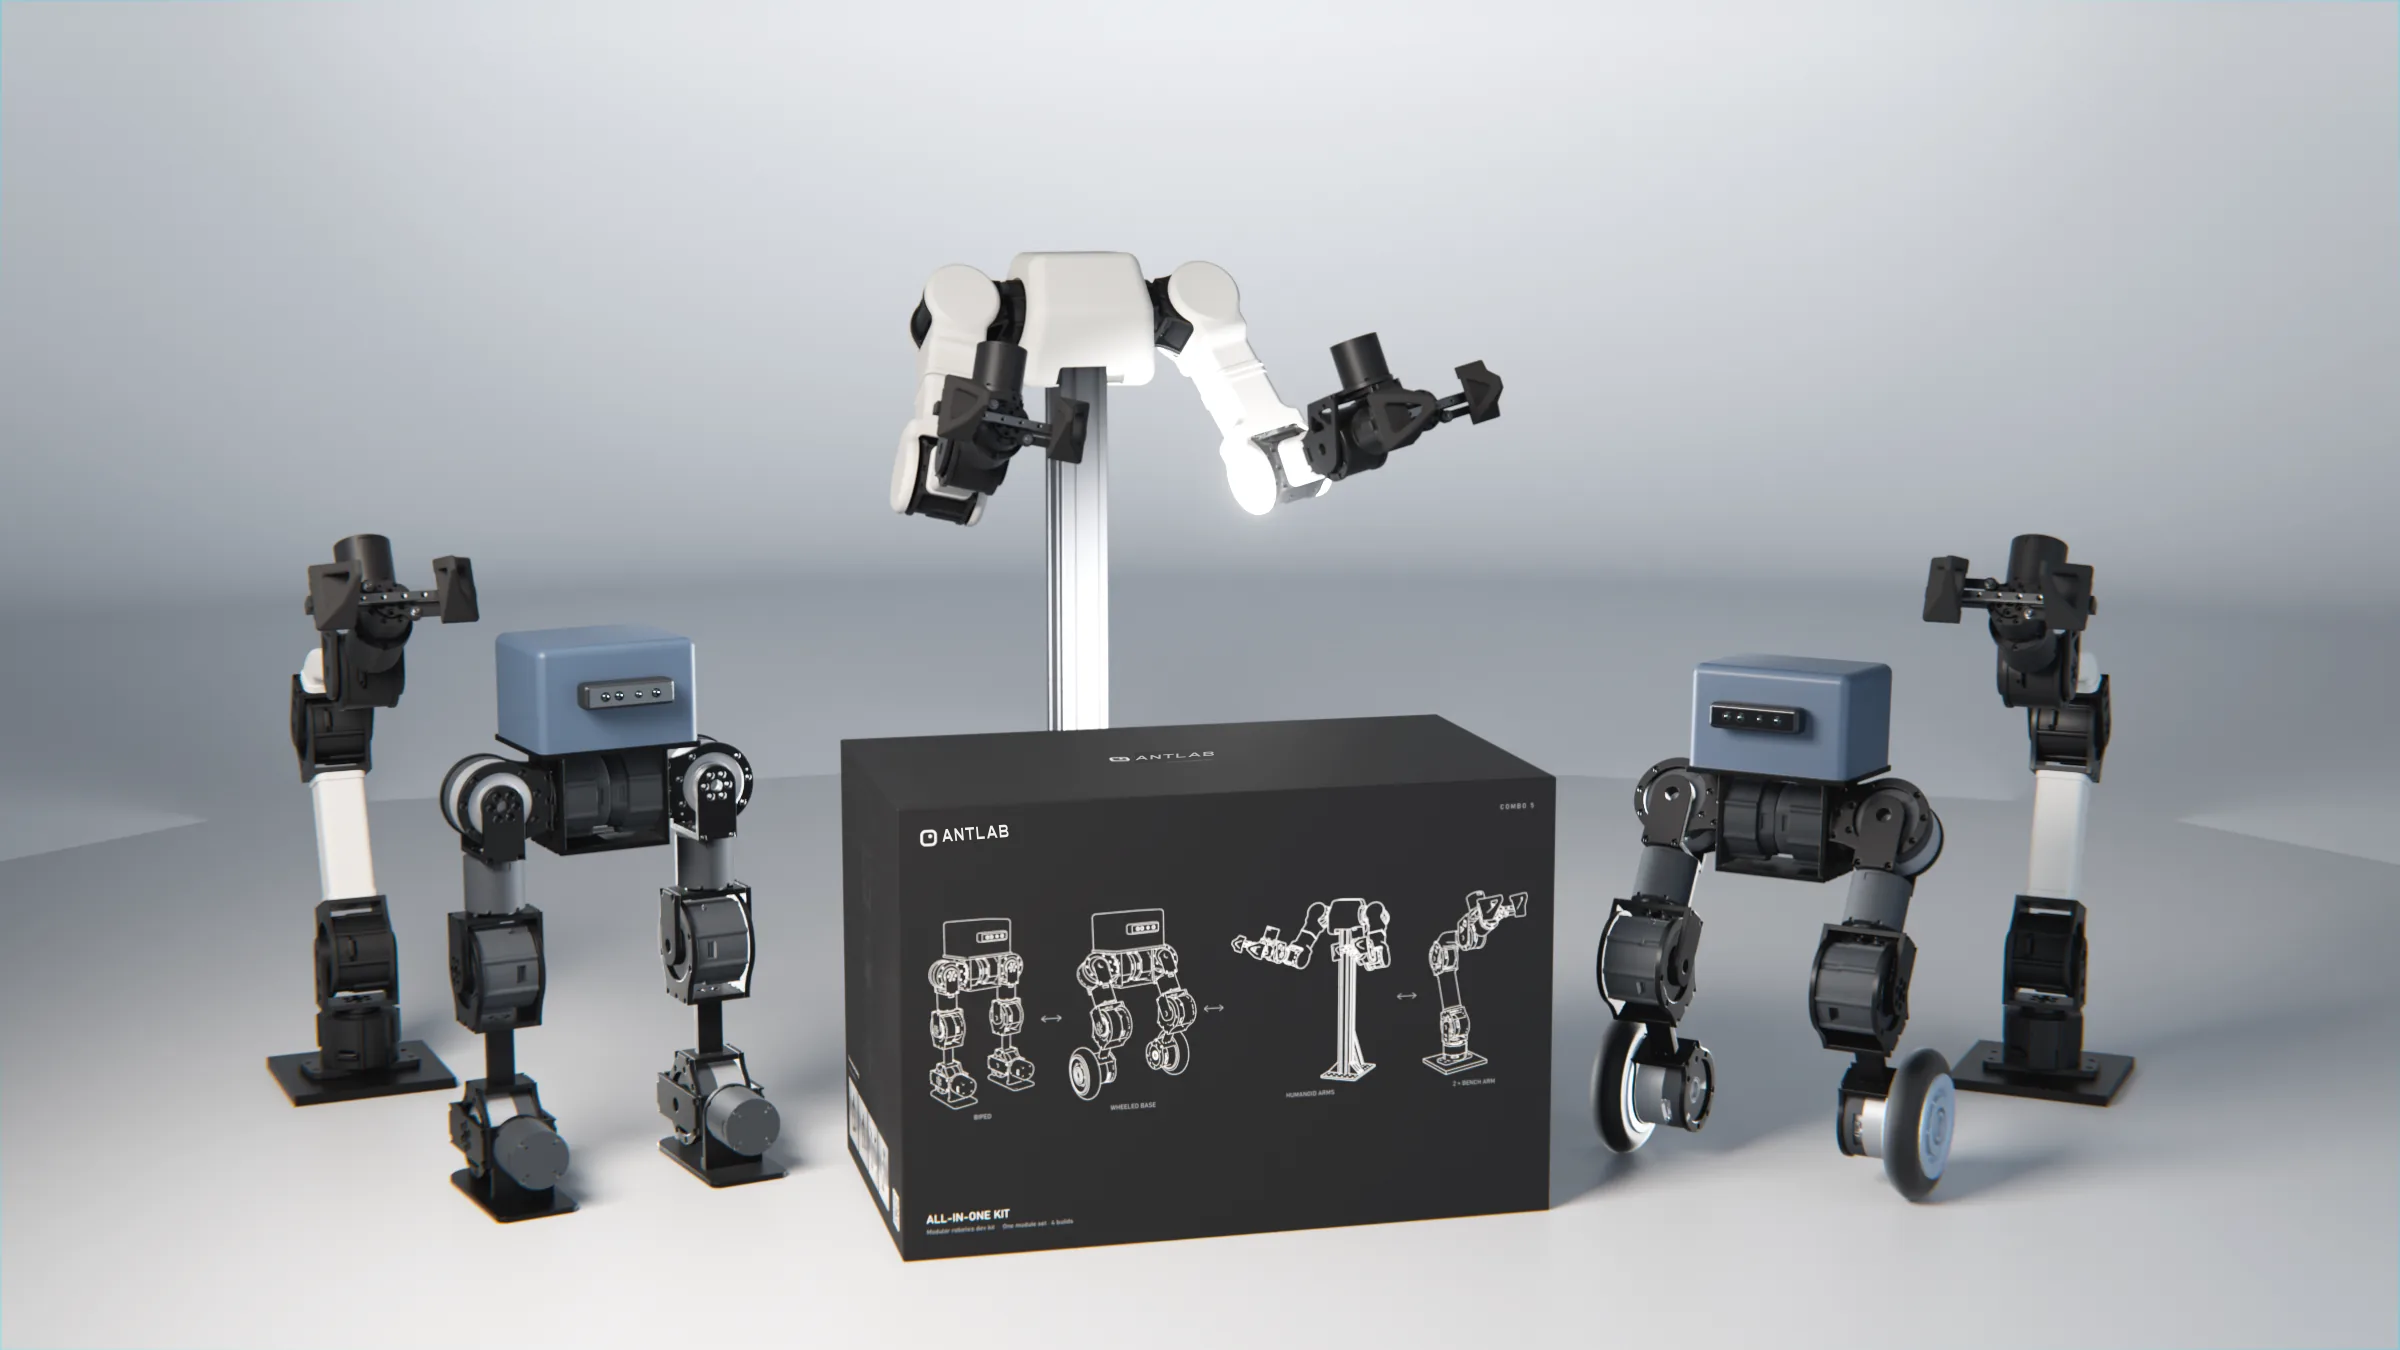
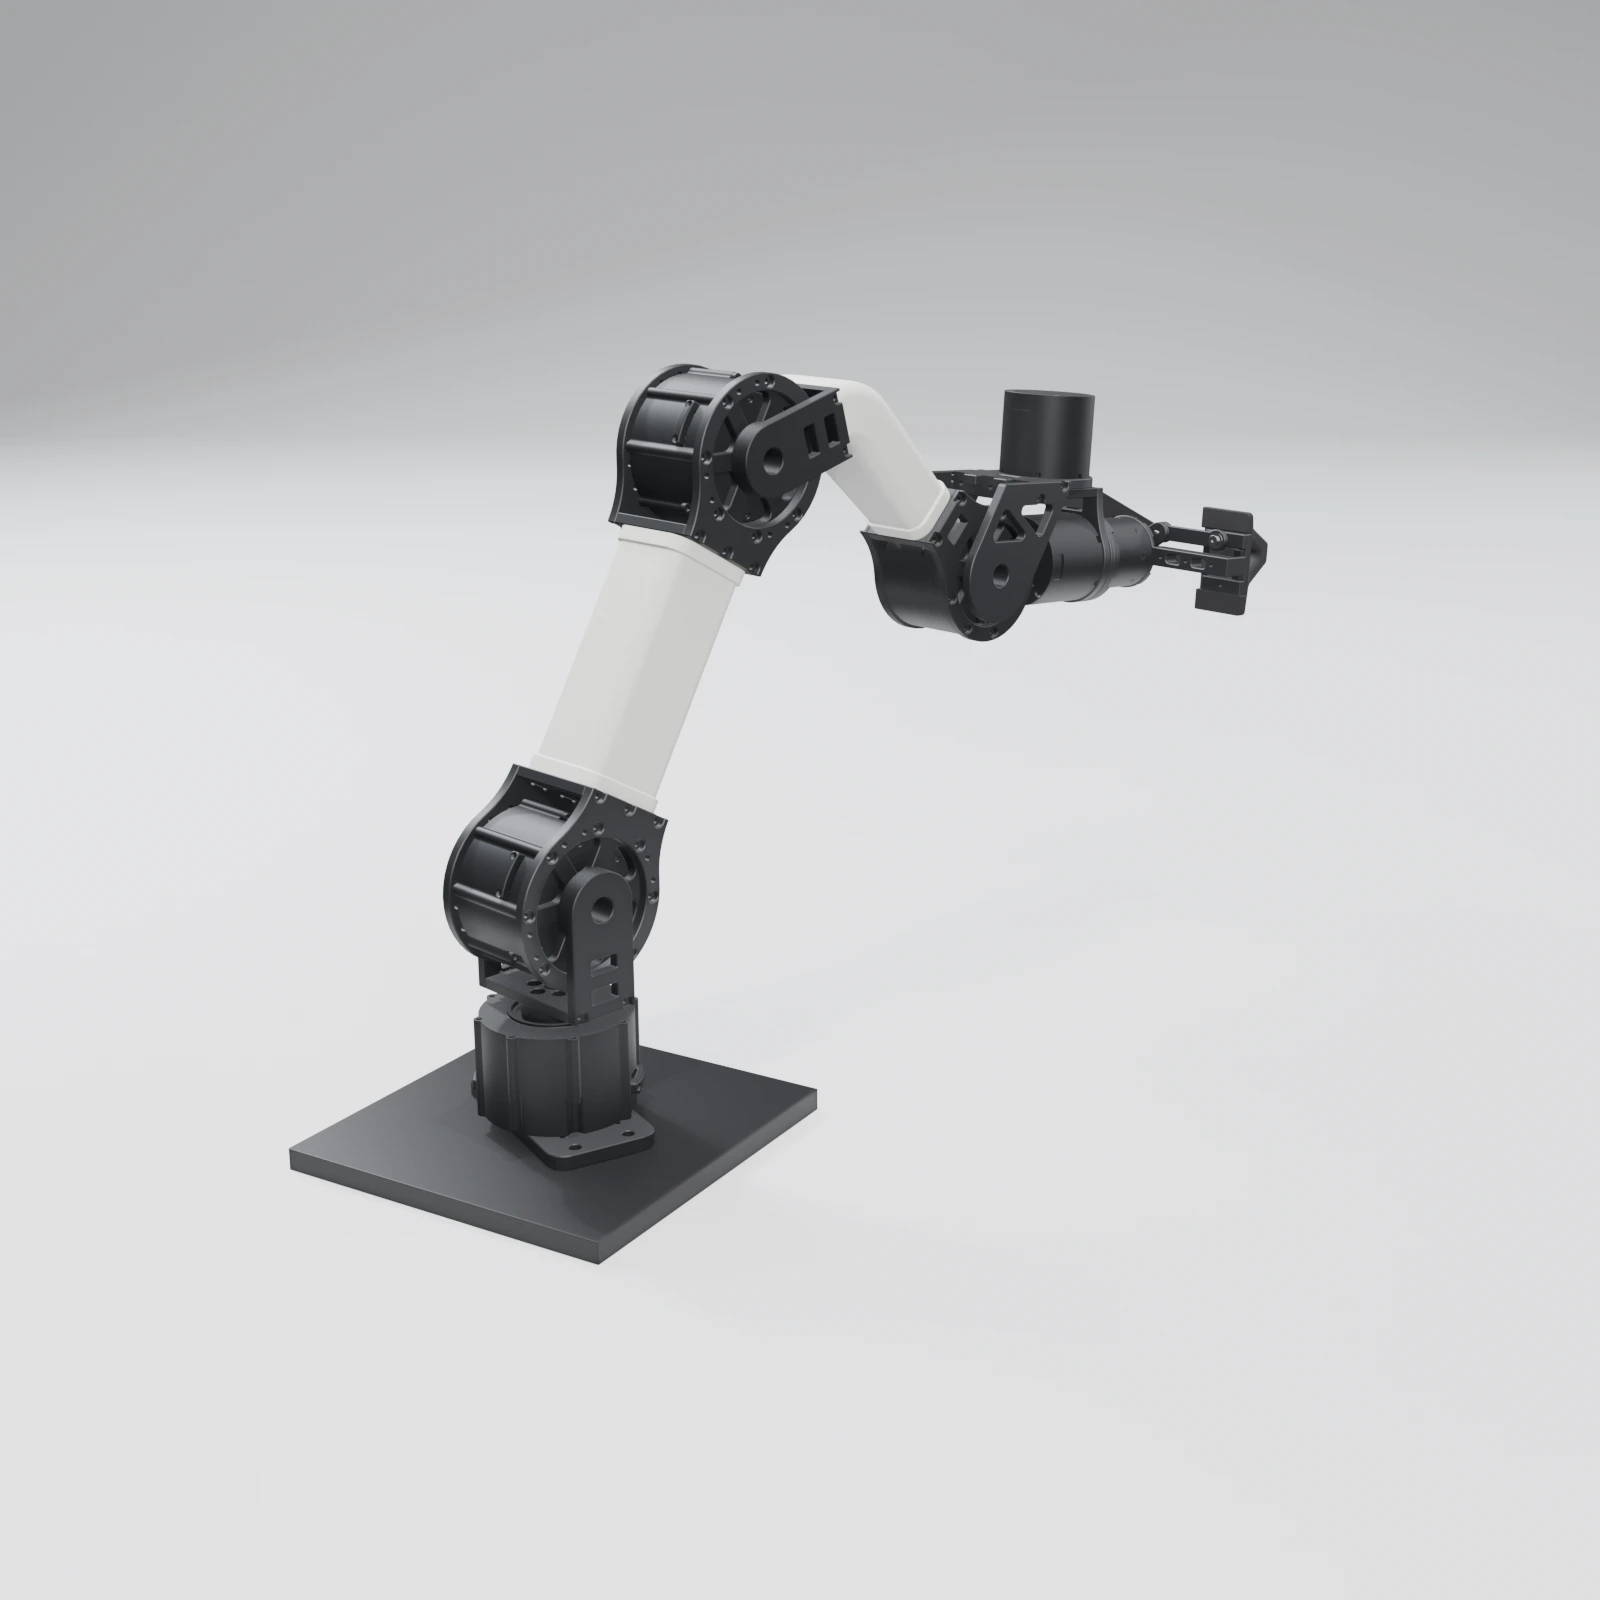
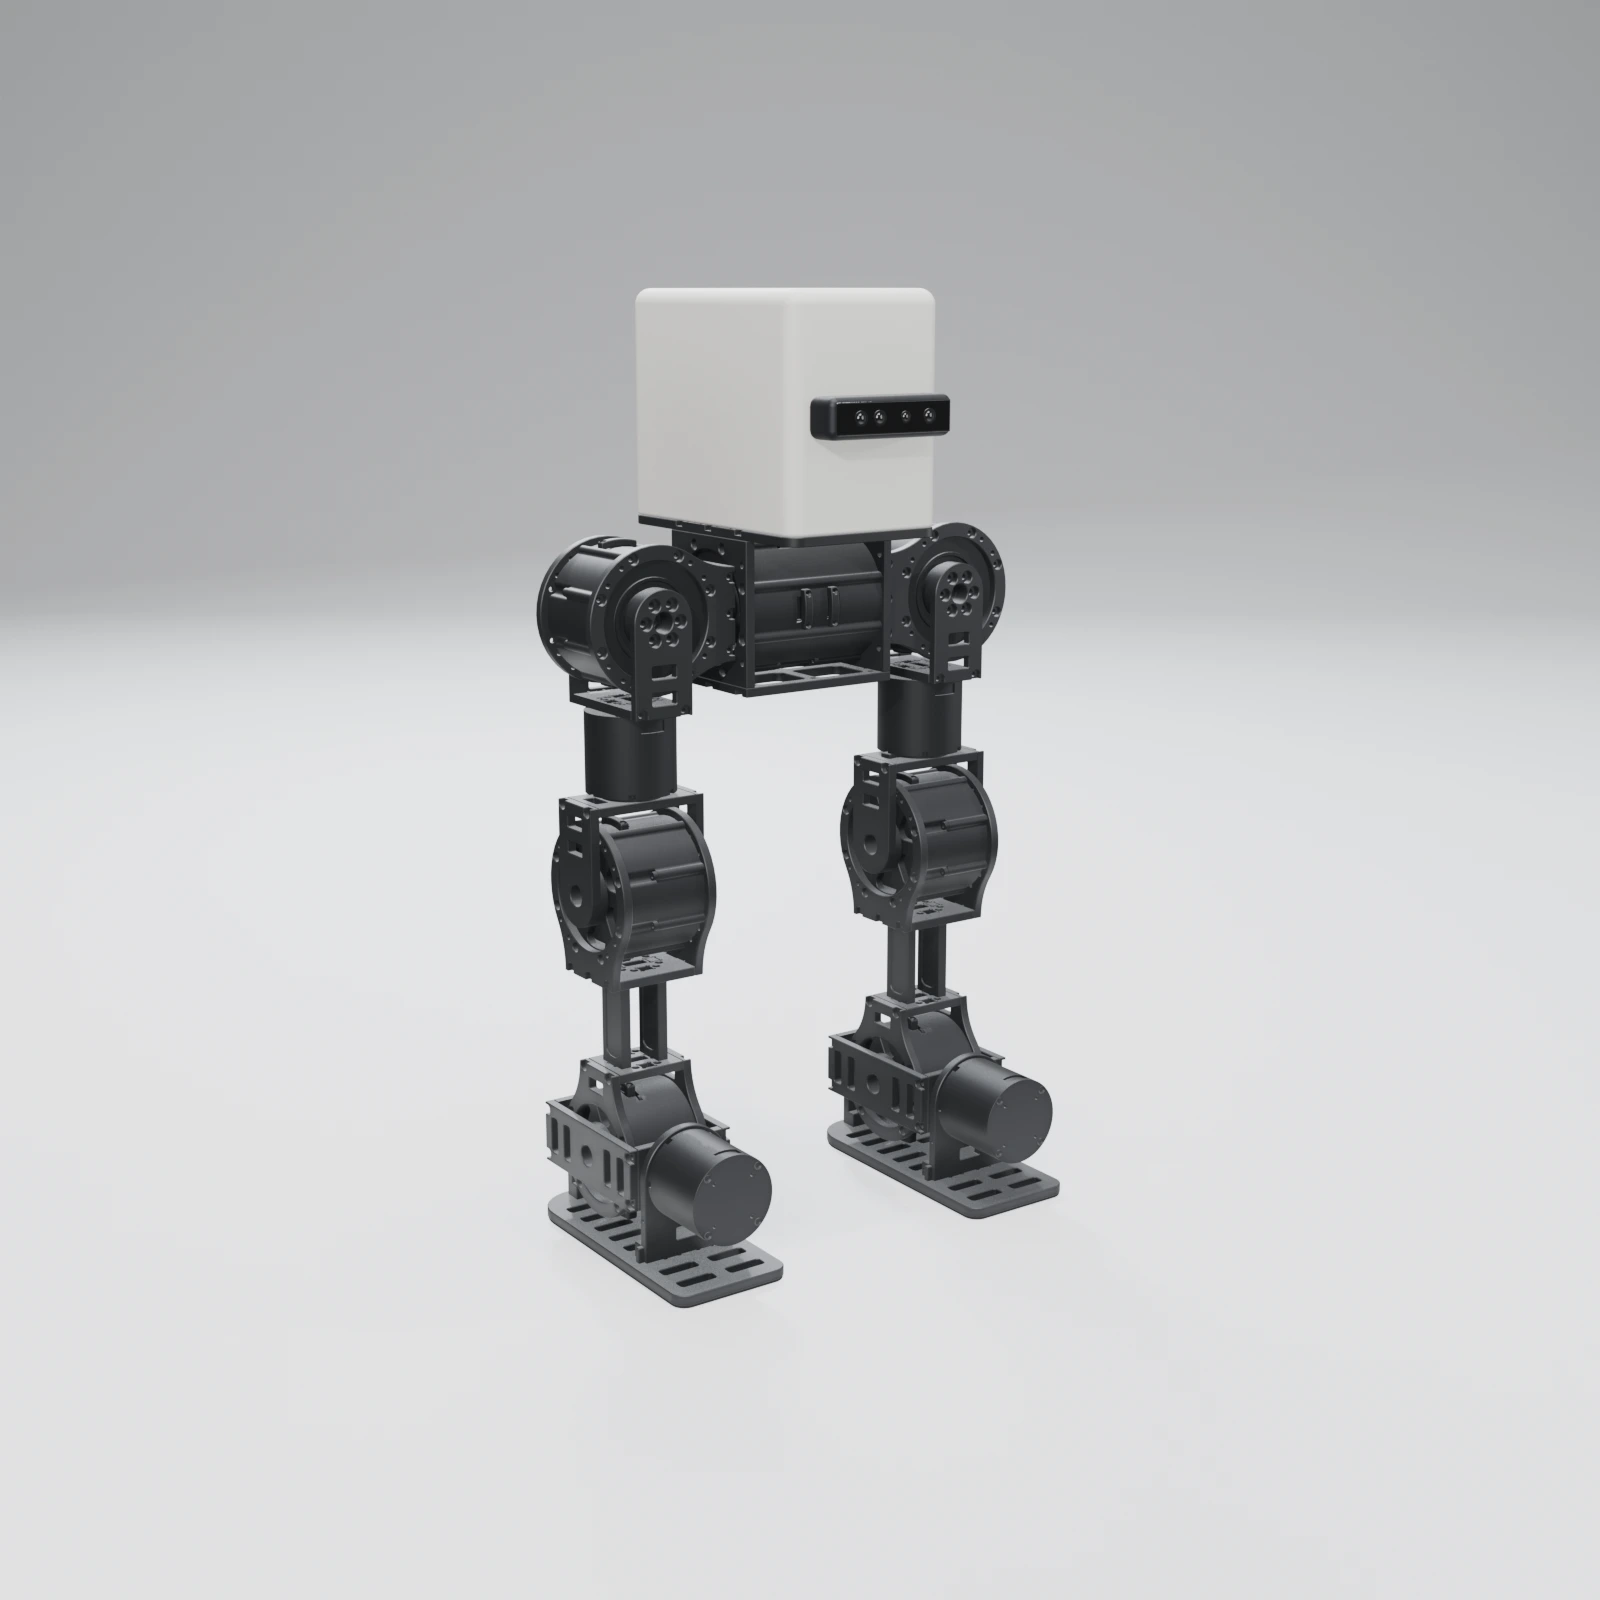
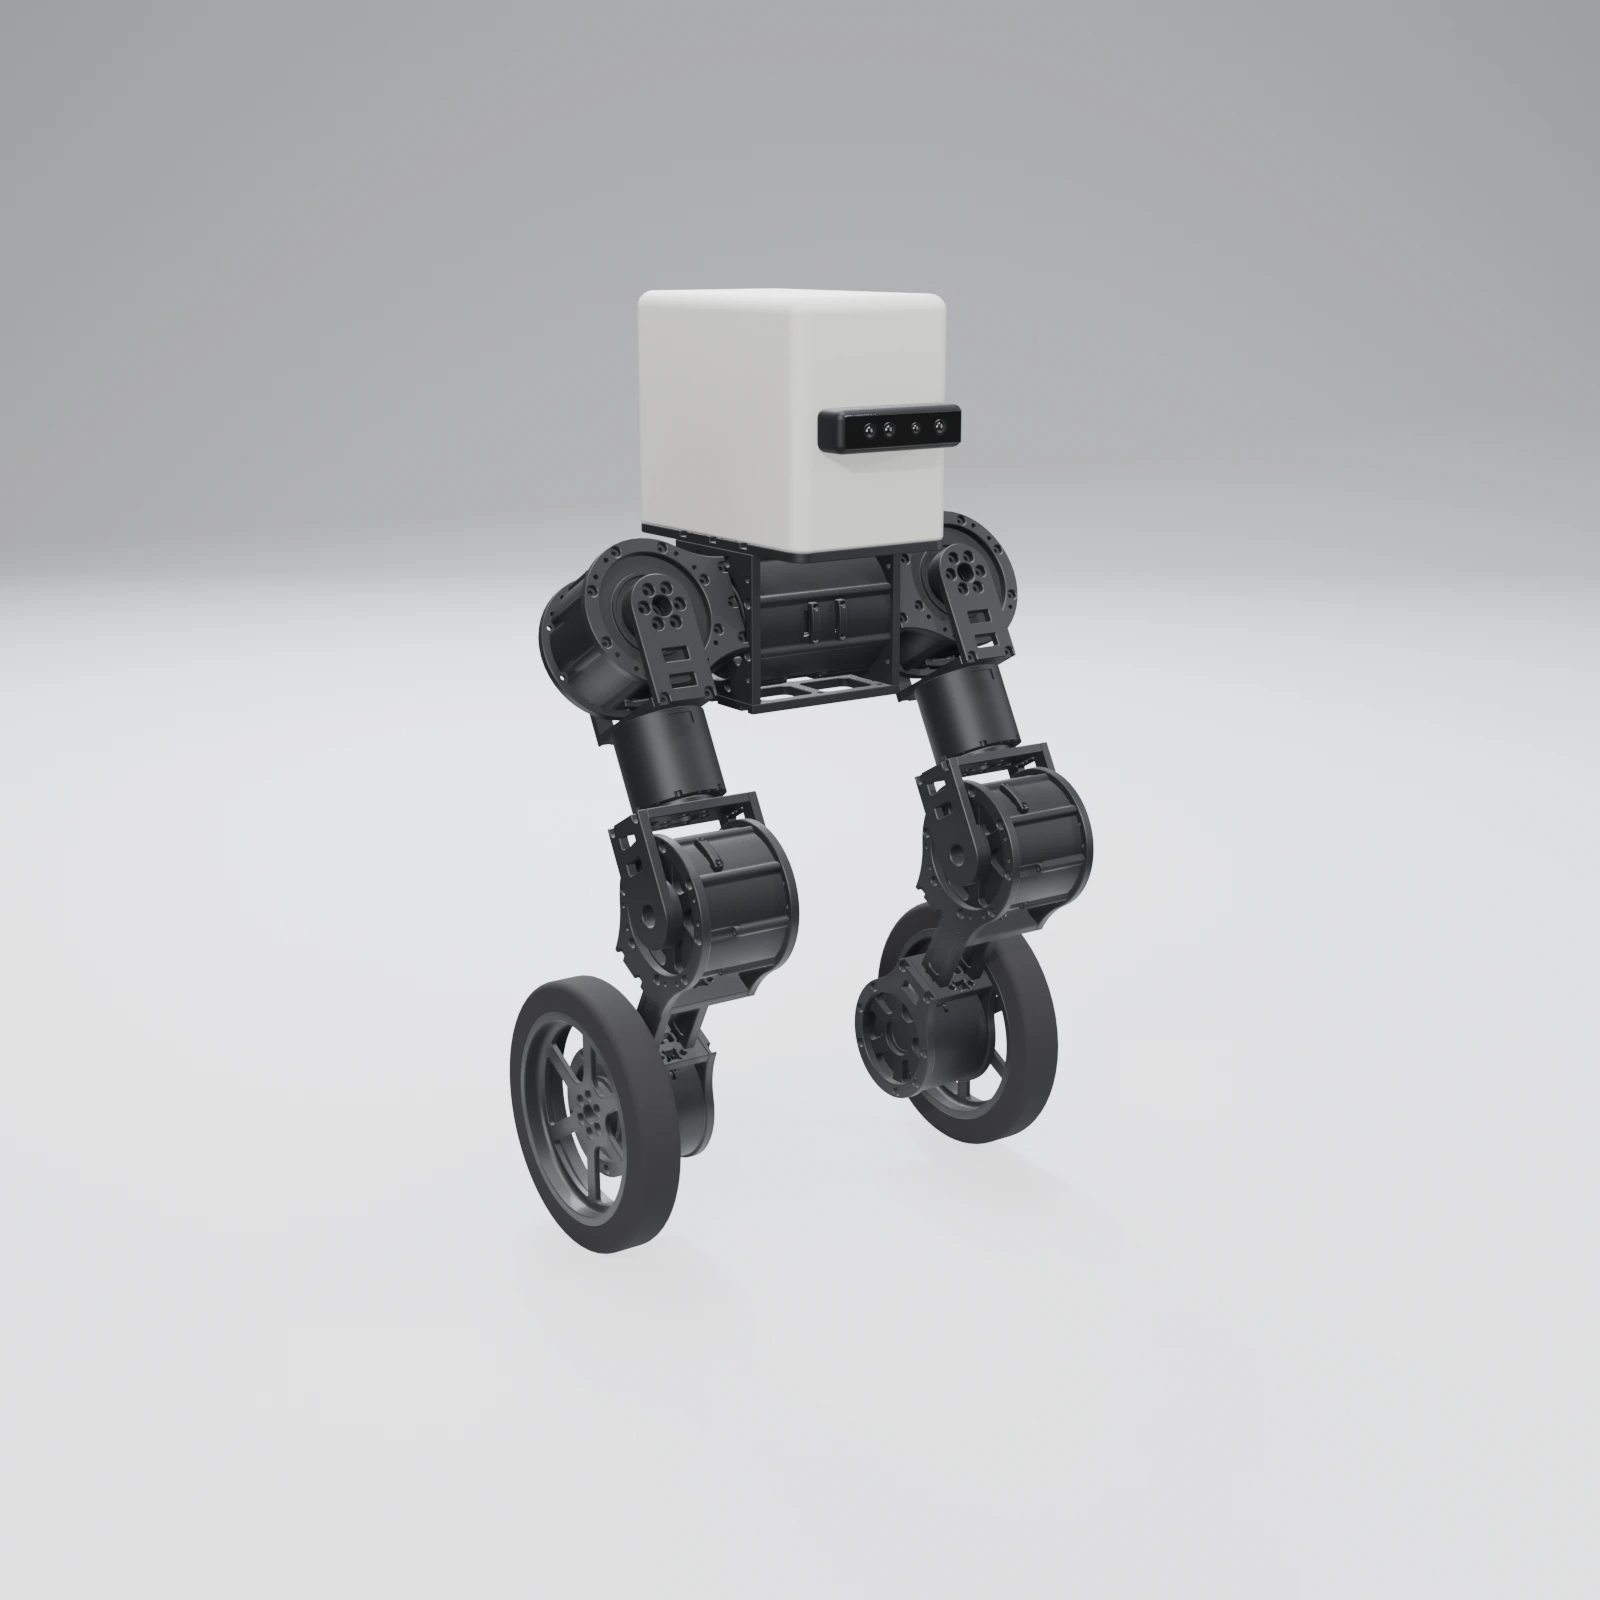
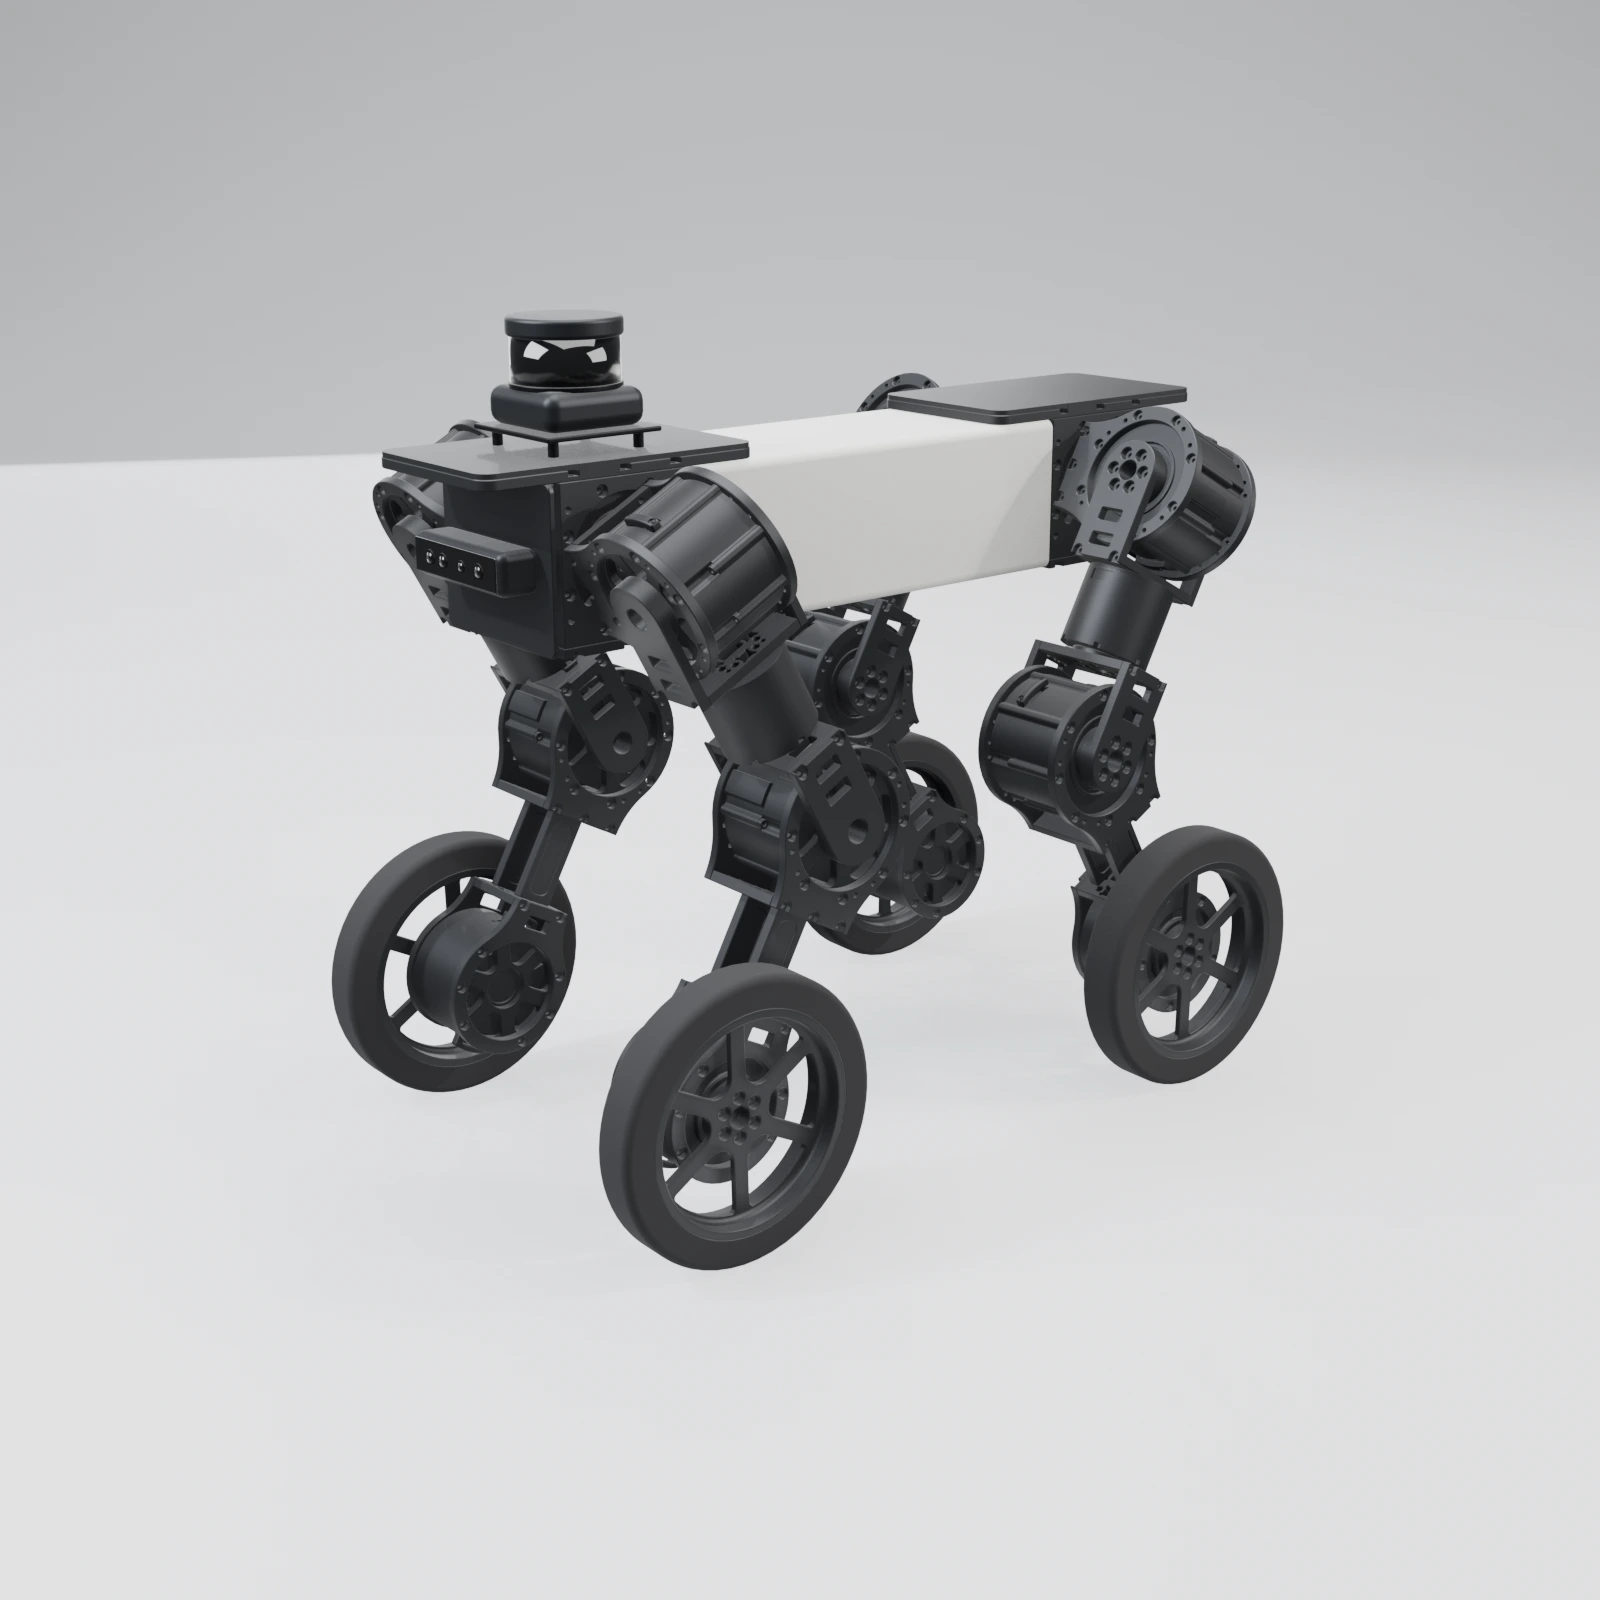
All-in-One
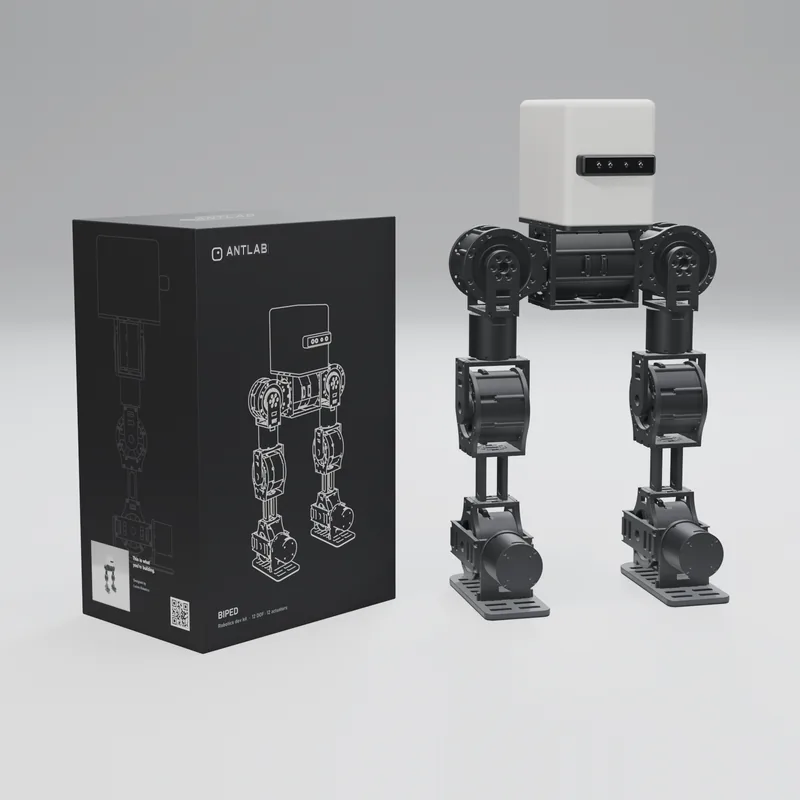
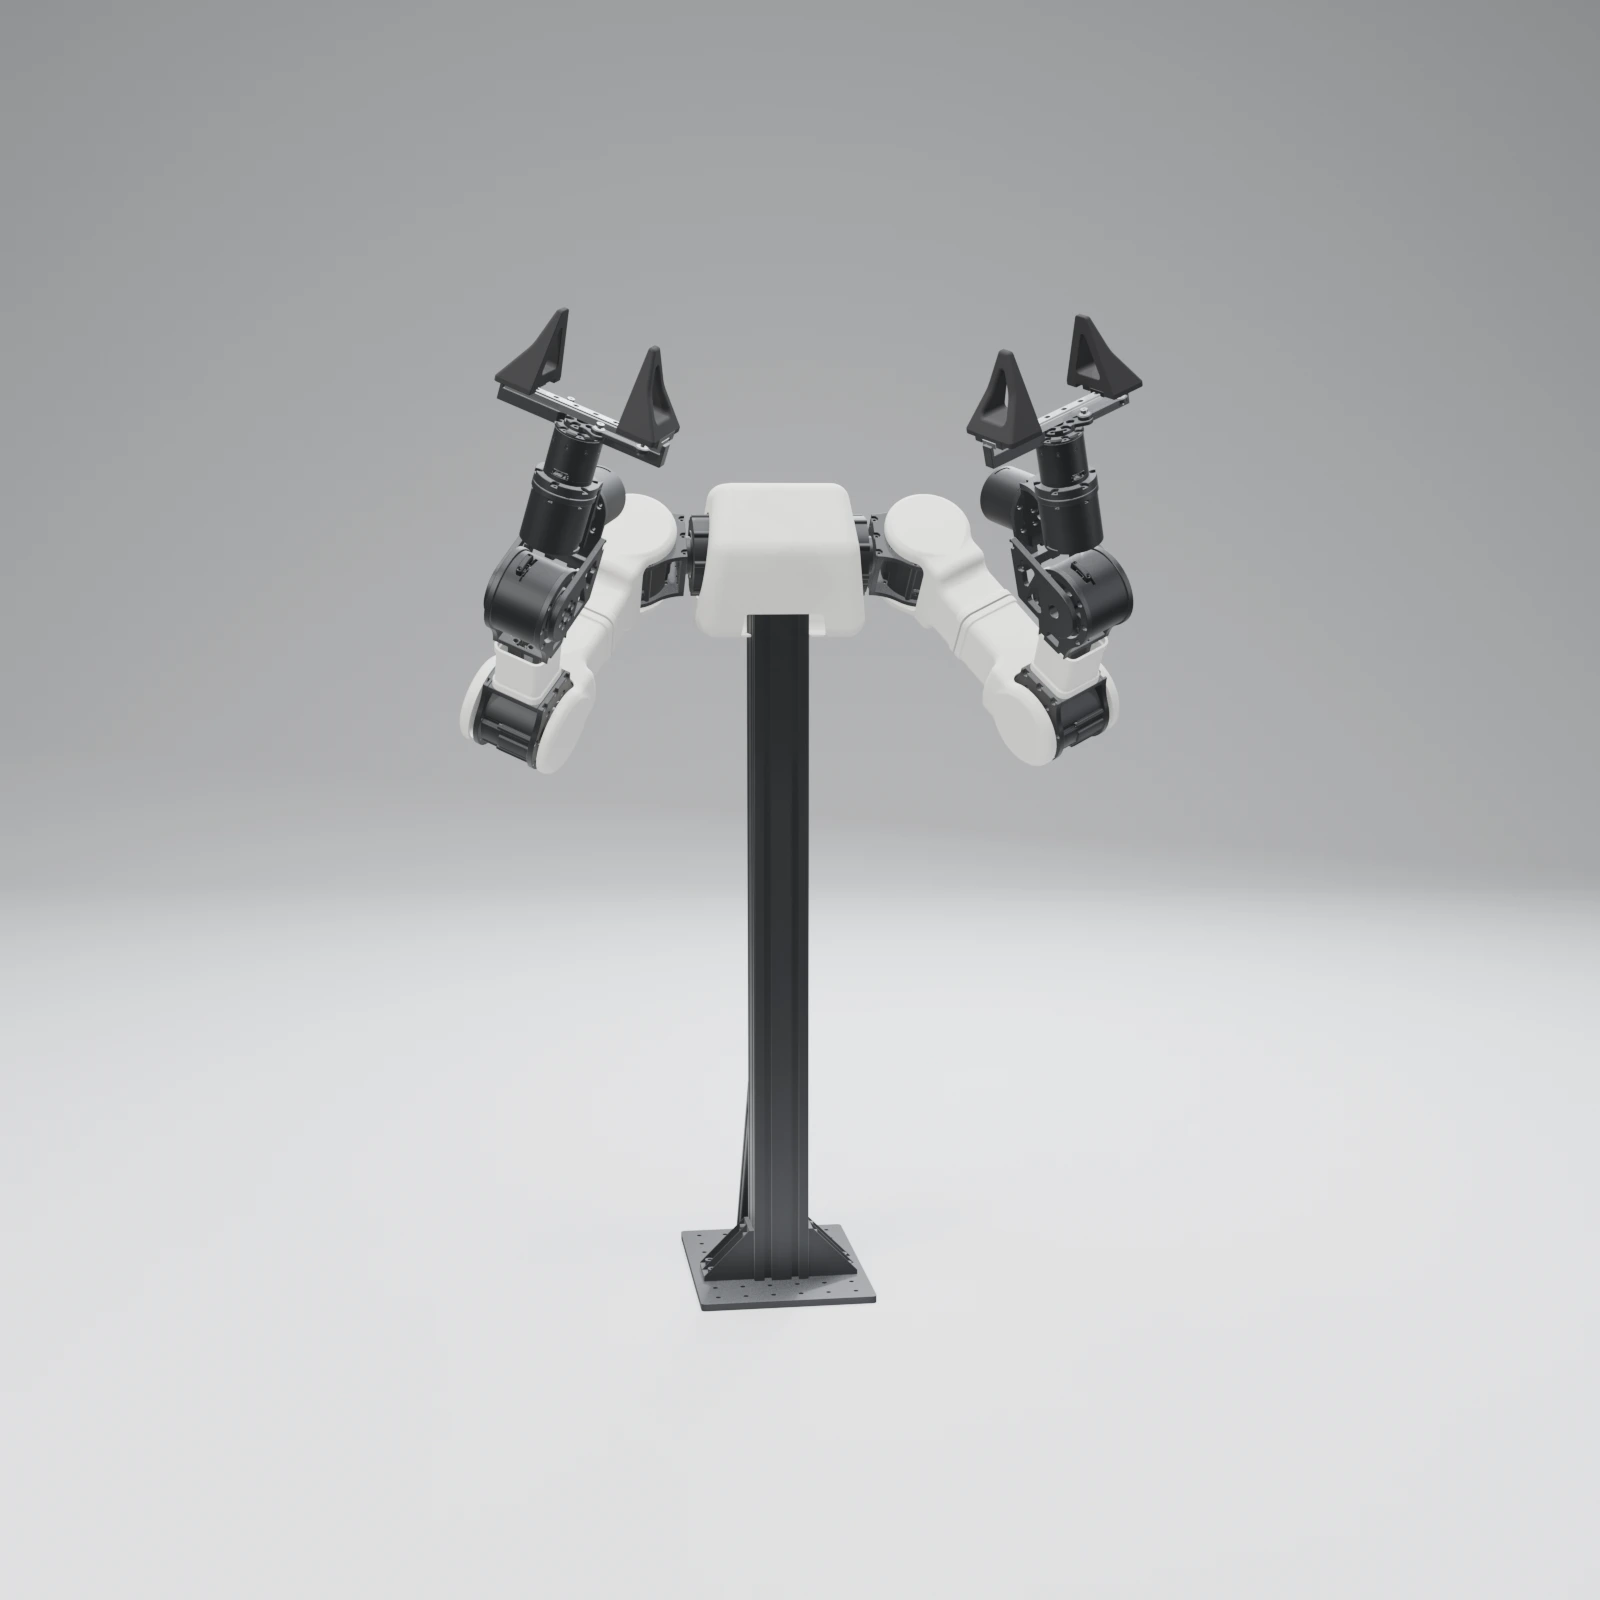
One Kit, 4 embodiments · Biped ⇄ Wheel ⇄ Humanoid Arm ⇄ 2 armsOne actuator set and every conversion kit. Walk, roll, and manipulate with two separate arms or both on the stand.
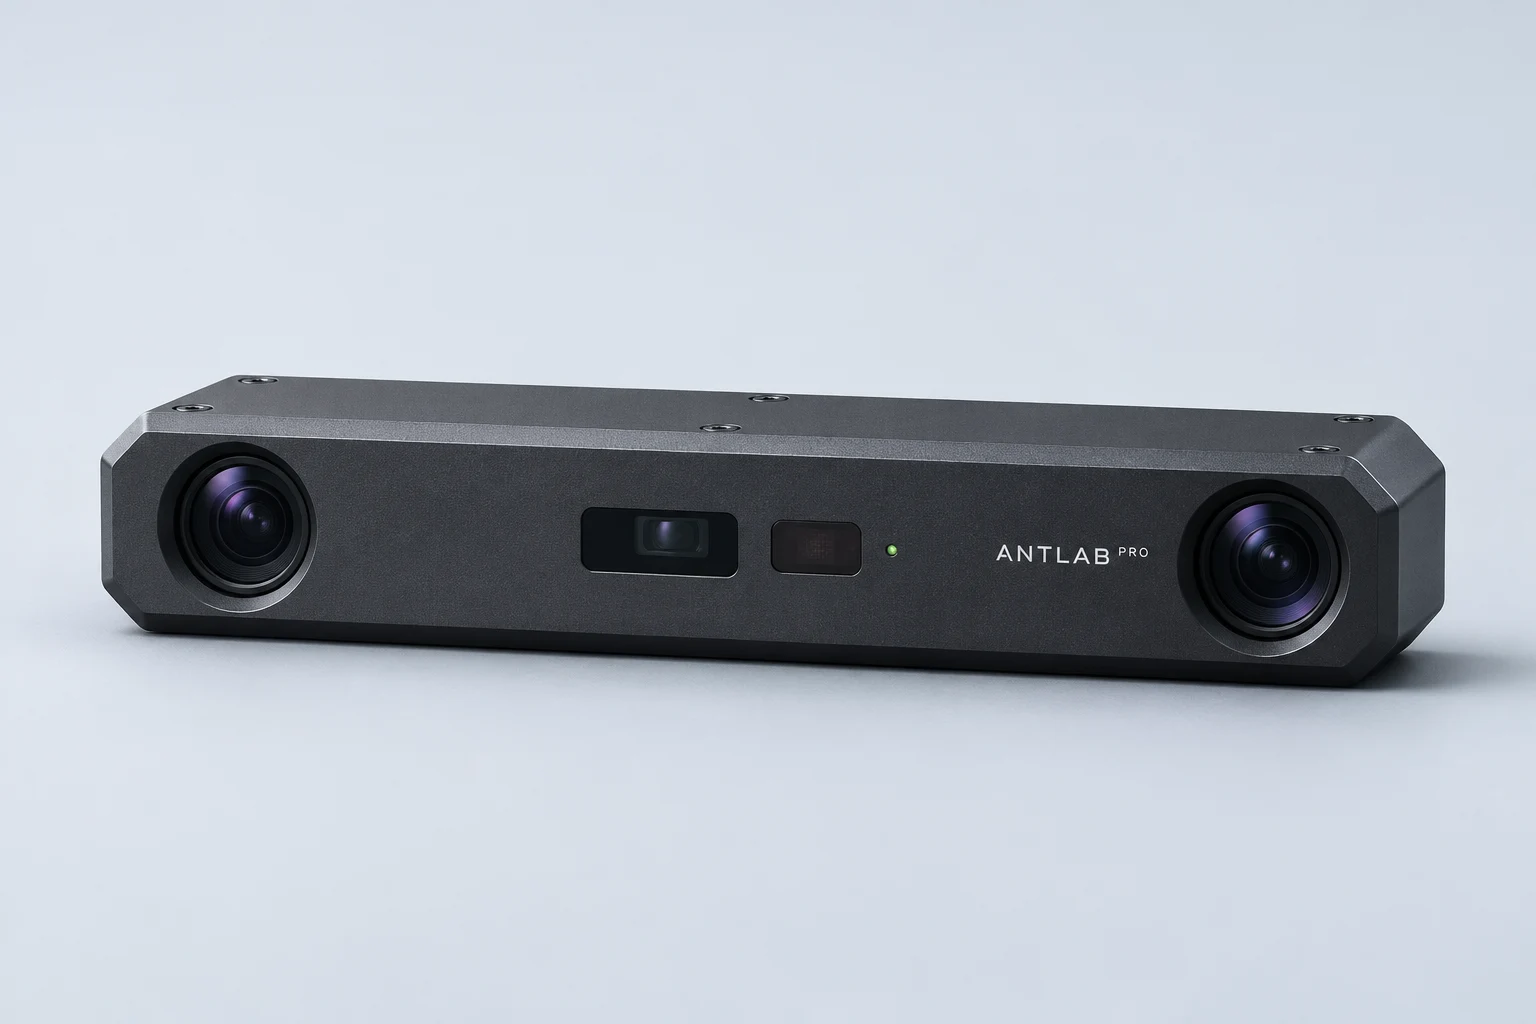
Programmable biped, wheeled, quadruped and arm robots for developers, on the same actuators and open SDK. Legged and wheeled builds carry an NVIDIA Jetson GPU computer on board. Buy one, or combine them.
Pre-orders open soon · fully refundable any time before your robot ships
Same actuators · 5 builds
EDU Edition
Unbolt the legs with a hex key. Every actuator is field-replaceable, with no soldering.
Replug the CAN bus, add two actuators, and fit the gripper. Nothing to re-wire.
Same actuators, same controller, same host software. Flash the arm firmware branch and start training.
Every bundle is one actuator set plus conversion kits. Build one robot, then rebuild it as the next with a hex key.
One actuator set and every conversion kit. Walk, roll, and manipulate with two separate arms or both on the stand.

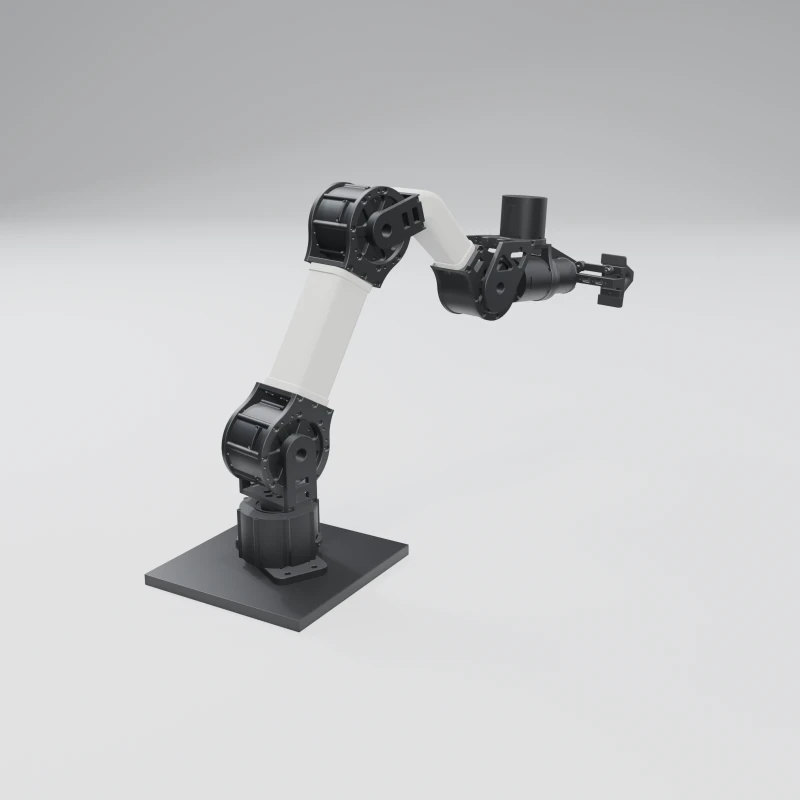
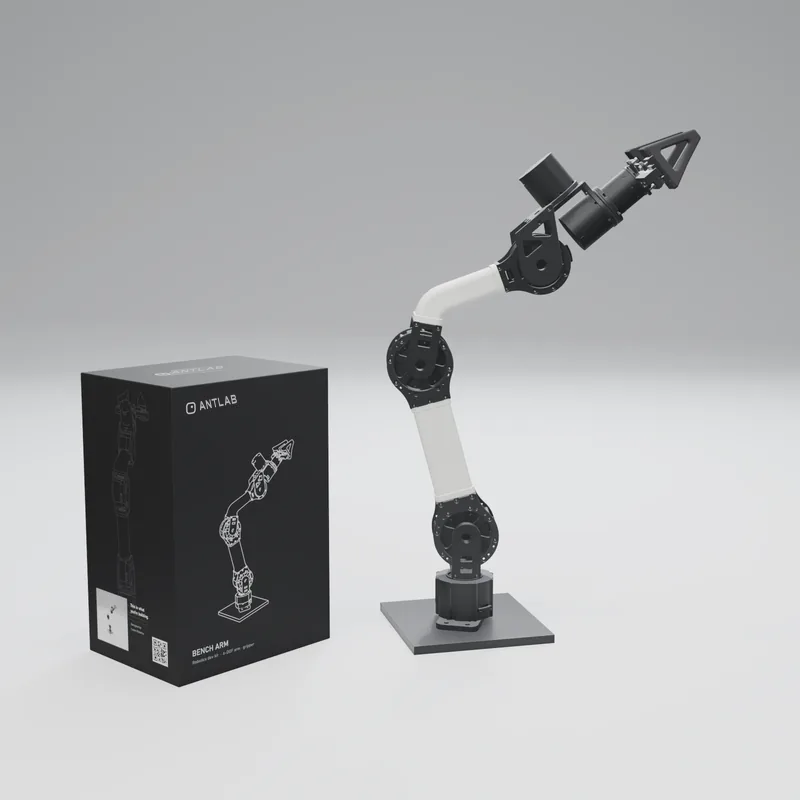
A 7-DoF manipulator with a compliant gripper. The entry kit for individual developers.

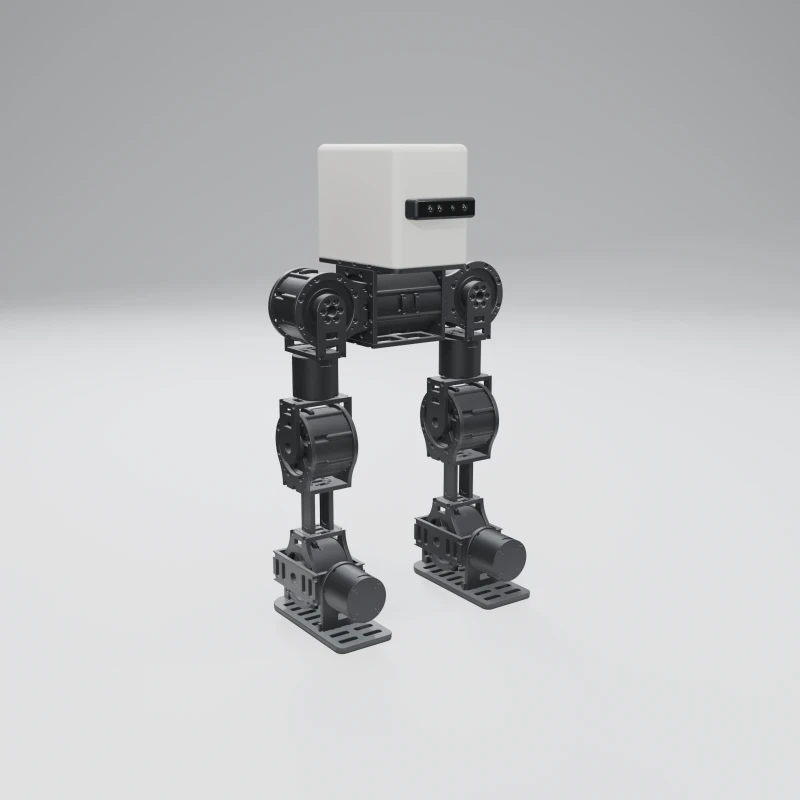
Built for training your first RL locomotion policy, or your tenth.
Shipping, tax and duties are quoted for your address and invoiced before dispatch. Prefer a single robot? See every build · Pre-order terms · Refund policy
Five robots, one actuator set. Leap, climb, map, stack and build, each from the same modules.
Each build reuses the same actuators, controller and firmware. Buy one on its own, or pair two in a bundle.

Most robot kits become paperweights the day a servo dies. ANTLAB is designed the other way round.
Every joint is symmetric, every connector is keyed, and every actuator is field-replaceable without a soldering iron.
Every line of firmware and every SDK primitive is on GitHub under MIT. Fork the controller and write your own policy interface.
LeRobot integration, MuJoCo XML, Isaac Sim scenes, and starter notebooks for ACT, SmolVLA and RL locomotion.
Purchase orders, formal quotes and custom configurations, including builds without compute for labs that bring their own. Tell us what you need.
Purchase order or quoteEmail us and we’ll prepare a formal quote for your institution.
Several kits at onceEquip a class or several research teams, quoted together.
Teach locomotion and manipulationOne kit covers both, so a class can move from RL walking to imitation learning.
Repair it yourselvesSpare actuators swap in minutes, so a broken joint doesn’t end the semester.
Locomotion and manipulation from the same kit, with open firmware and NVIDIA compute.